GR8BOT
An Autonomous solar panel cleaning robot designed and built by MEng team 8
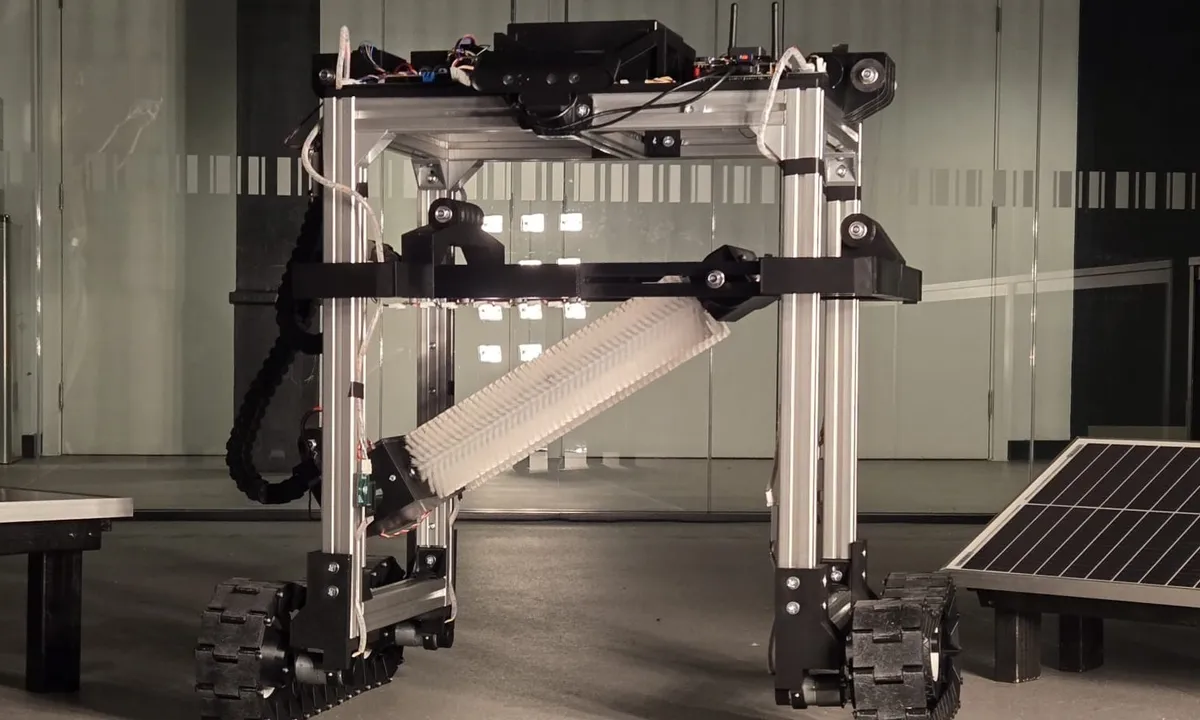
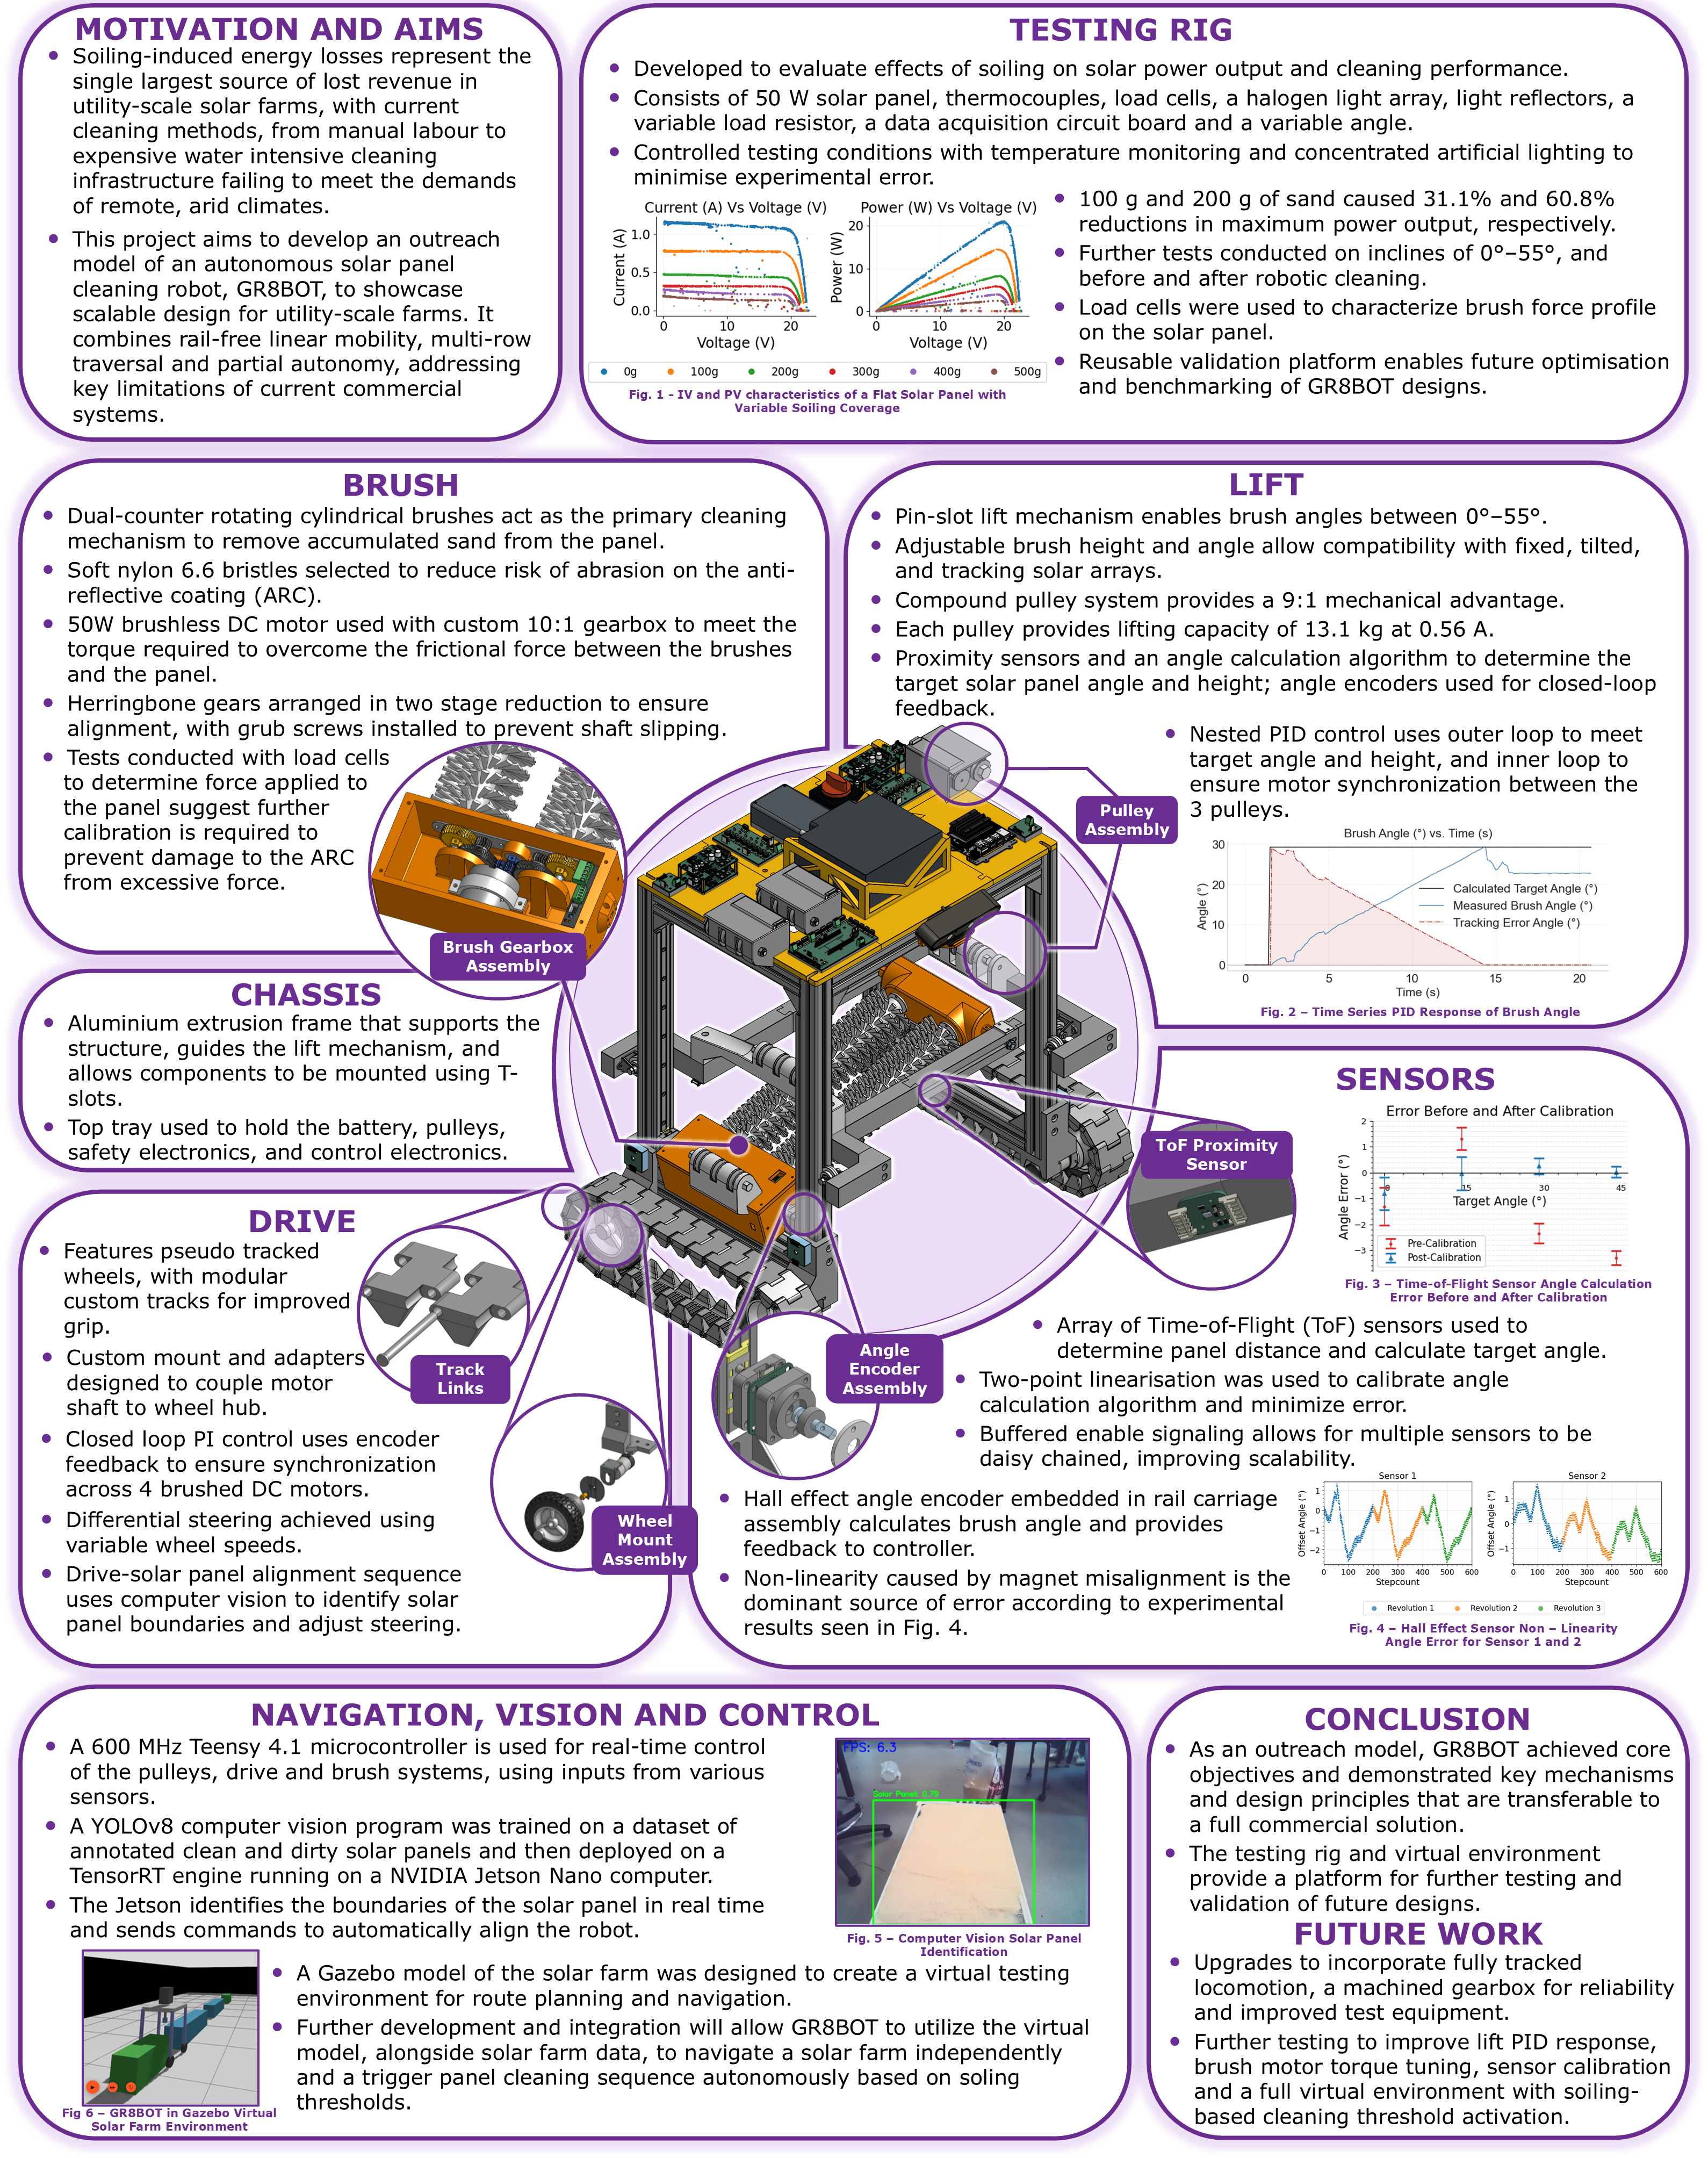
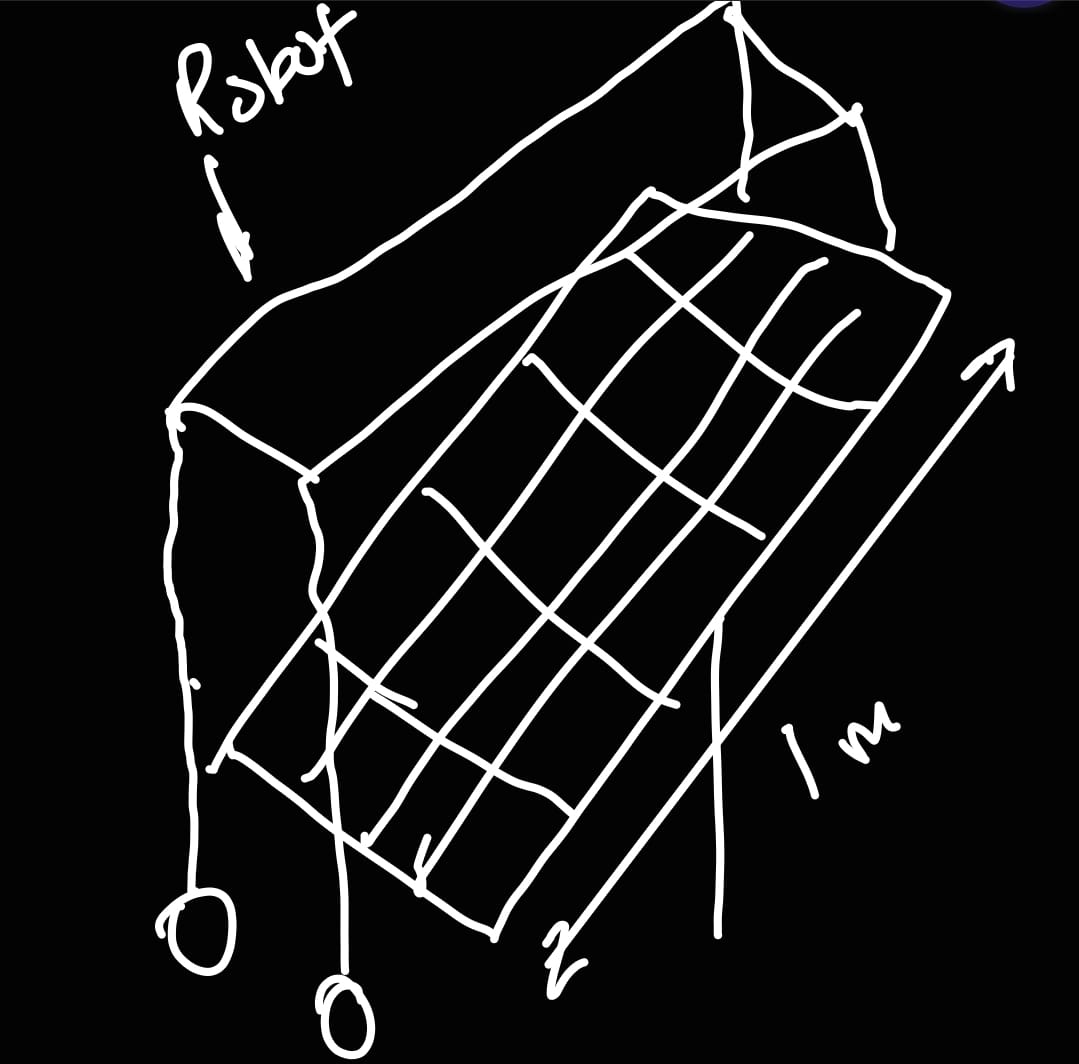
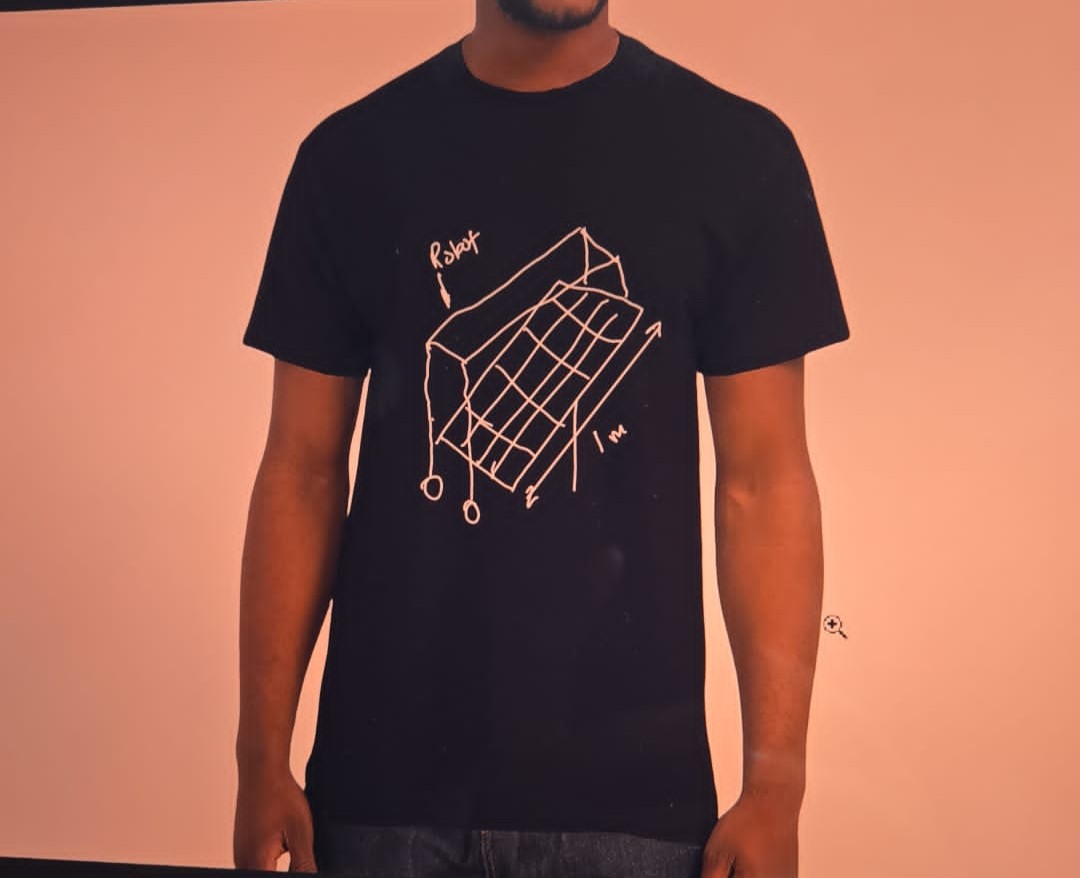
GR8BOT was designed as an autonomous solar panel cleaning robot concept that could later be scaled to utility scale solar farms. When we started our MEng project we were given complete freedom when it came to the direction our design would take. We managed to come up with this concept and built it within the year. It travels along the ground to traverse solar panel rows and uses a pin-slot mechanism and pulleys to adjust the angle of the brushes, matching any angle from 0-55°. We turned our robot’s original sketch into some merch as a reminder of our humble beginnings:
Project Highlights:
- Full CAD assembly of GR8BOT, with most parts including the lift pulleys, horizontal bar, top tray, brush housing, gearbox, wheel mounts, tracks and more designed in house and 3D printed
- Time-of-flight (ToF) sensor array to determine the target solar panel angle and hall-effect angle encoders to track the current angle
- Pulley-based lift system to which adjusts the height of the brush housing and horizontal bar, therefore adjusting the angle of the brushes
- Nested PID control for pulley motor synchronisation and to meet target angle and height
- Pseudo tracked wheels to improve grip and manoeuvrability
- YOLOv8 computer vision program running on a Jetson nano to identify solar panel boundaries
- Virtual Gazebo model of the solar farm to allow for future autonomous navigation using ROS
- Custom distribution and optocoupler PCBs to simply wiring and protect high value electronics
- Testing rig to quantify solar panel cleaning efficacy measuring current, voltage, power, temperature and force.