ESP48
A line-following buggy by team 48 for the 2nd year embedded systems project
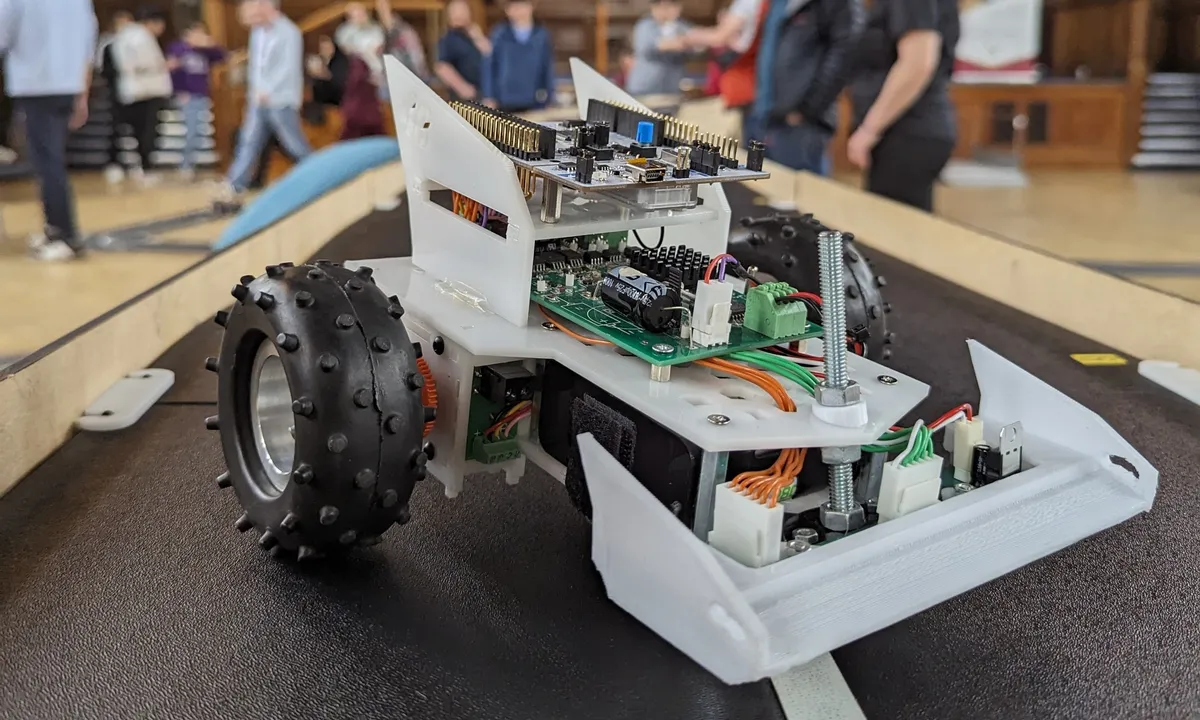
For the 2nd year embedded systems project students are tasked with designing and building a line-following buggy in a team of 5. Over the course of the year we had to complete several labs, technical demonstations and a final race between the top scoring teams. Our buggy won the race setting a new record of 41.4s and remains the reigning champion since. My teammate has written extensive documentation on the software behind the buggy which can be found here https://github.com/Amrlxyz/esp-lfr-buggy.
Project Highlights:
- Custom arcylic chassis design
- PI motor speed control using PWM
- PID line-following algorithm
- Python logger for tuning PID values
- Custom sensor array PCB
- Individual sensor and motor characterisation
- Wireless control using bluetooth commands
- Technical report writing to justify design choices